Precise GNSS positioning in under a second
From geodetic stations to low-cost receivers: multi-GNSS SPP, PPP, RTK and TDP with least-squares, Kalman-filter or factor-graph solvers.
Install in one command
curl -fsSL https://raw.githubusercontent.com/pppx-dev/pppx/main/install.sh | bashAny distribution with glibc ≥ 2.31 (Ubuntu 20.04+). Also works in WSL.
curl -fsSL https://raw.githubusercontent.com/pppx-dev/pppx/main/install.sh | bashApple silicon, macOS Monterey or newer, with Homebrew.
curl -fsSL https://raw.githubusercontent.com/pppx-dev/pppx/main/install.sh | bashRun in Git Bash (bundled with Git for Windows) or MSYS2.
Why PPPx
Fast, accurate, and not just for geodetic receivers
Fast
A full day of 30 s data — 2880 epochs — is processed in under a second on a single CPU core.
Works with low-cost receivers
Process u-blox and smartphone data, with results published in peer-reviewed research.
Accurate
Centimetre-level kinematic and millimetre-level static positioning.
Free for research
Free for academic research, teaching and other non-commercial use.
Examples
Example with geodetic receivers
From RINEX to a solution
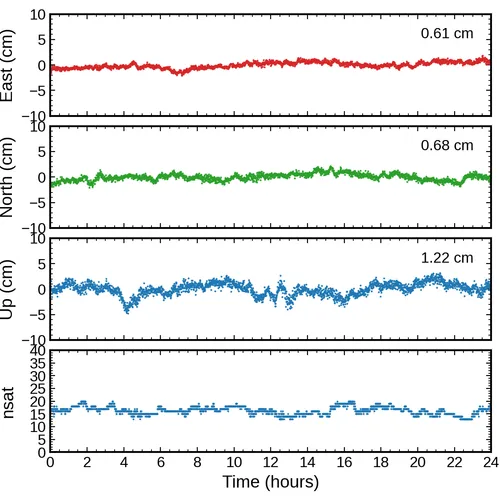
Hand PPPx your RINEX observations and satellite products, choose a mode and a solver, and a positioning solution comes back in under a second.High precision
Centimetre-level kinematic and millimetre-level static positioning, with optional PPP-AR.
Fast
A full day of 30 s data — 2880 epochs — solved in under a second.
Automated
The pppx.sh wrapper downloads the required products and runs the processing in one command.
Examples
Example with low-cost receivers
Precise geodetic parameters estimated with low-cost receivers
Glacier monitoring with u-blox receivers
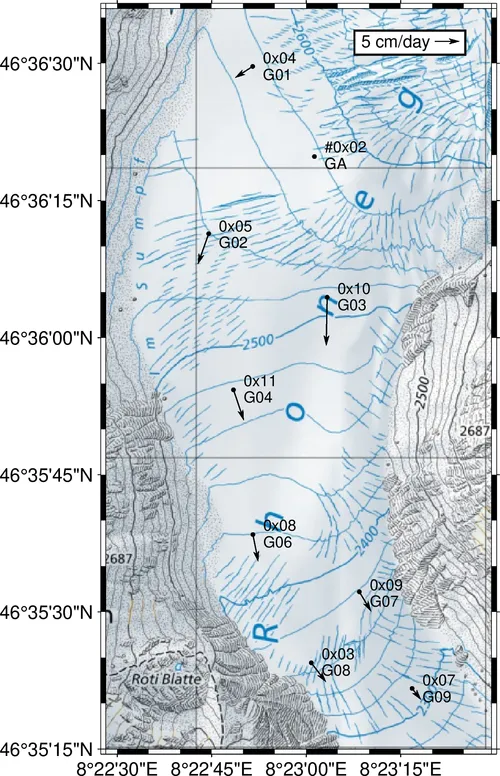
The map shows the velocity field of the Rhône Glacier, derived with PPPx from several months of u-blox data collected by HERMIT, a low-cost GNSS-seismic monitoring platform.
Tropospheric monitoring with smartphones
High-precision tropospheric delays estimated with PPPx from a u-blox receiver and a Google Pixel 4 XL, validated against a co-located geodetic station (Pan et al., 2024).
Robust to noisy observations
Factor-graph optimization with a robust loss down-weights outliers.
Capabilities
One tool, every positioning mode
Solution modes
SPP, PPP, RTK and TDP, with unified inputs, configuration file and outputs.
Constellations
GPS, GLONASS, Galileo, BeiDou and QZSS, with configurable frequency pairs.
Solvers
Least Squares (LSQ), Extended Kalman Filter (EKF) or Factor Graph Optimization (FGO).
PPP-AR
Ambiguity resolution with Observable-specific Signal Bias (OSB) products.
Easy to inspect
Visualize results in the web viewer, with the bundled Python script, or with RTKLIB.
Cross-platform
Runs natively on Linux, macOS (Apple silicon) and Windows.
Research
Used in 11 research works
Peer-reviewed articles, conference contributions and preprints.
Ionospheric data fusion with GNSS, GNSS-RO and satellite altimetry based on machine learning
M. Iten, S. Mao, B. Soja · Journal of Geophysical Research: Machine Learning and Computation (2026)
A deep ensemble transformer model for global ionosphere prediction and uncertainty quantification
S. Mao, J. Gou, B. Soja · Journal of Geophysical Research: Machine Learning and Computation (2026)
Probabilistic machine learning for slant total electron content modelling based on GNSS
A. Rüegg et al. · ESS Open Archive (2026) · Preprint
Start processing GNSS data today
Install locally for full control over the configuration, or upload a RINEX file and get a PPP solution in your browser.